One autonomy stack. Many missions.
Modular, standardised autonomy software that lets an aircraft sense, decide and navigate, even without GNSS, and plugs into new airframes through standard interfaces.
Three systems.
One autonomous stack.
The board, the battery and the brain: engineered to work together as one indigenous stack, or adopted one module at a time.
The brain: our lead product
Navigation, obstacle avoidance and precision landing run onboard in real time. Modular, standardised and vehicle-agnostic, so the same software serves ISR, logistics, casevac and more.
- GNSS-denied navigation, proven in simulation
- Scales from assisted to full autonomy
- Pilot takeover and failsafes respected
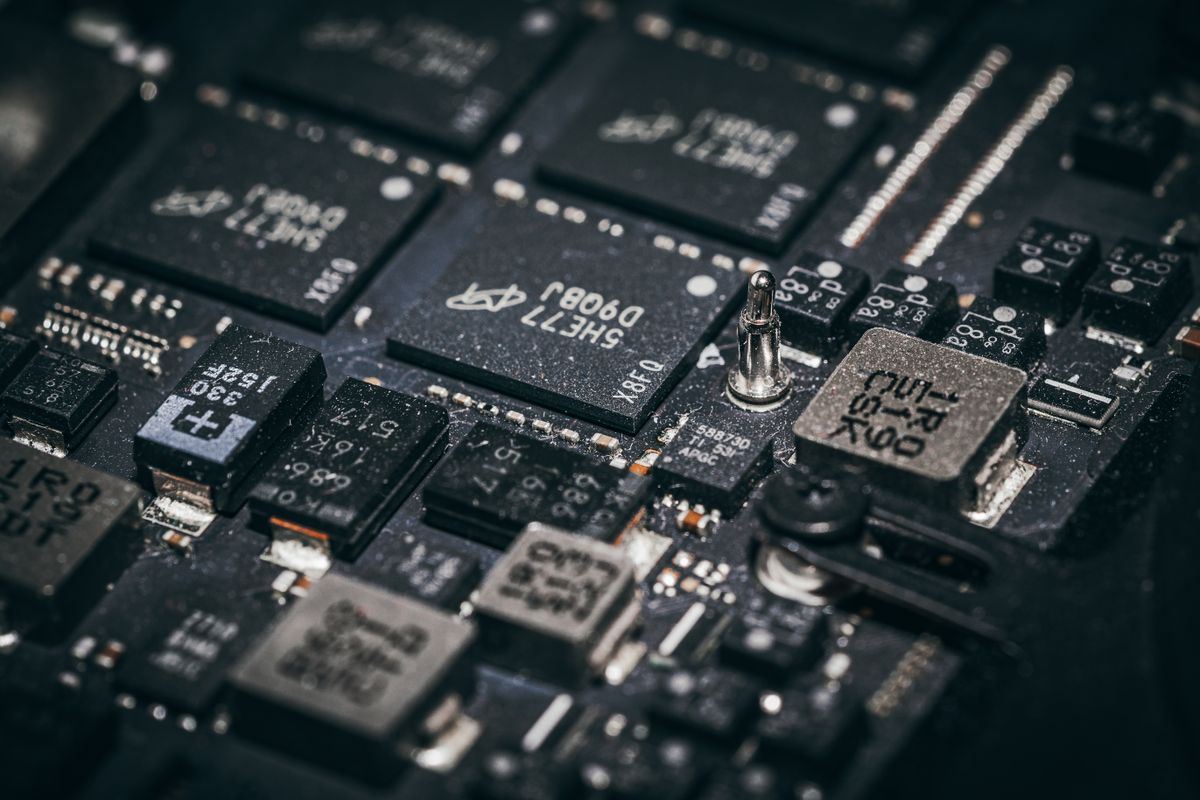
The board: integrated hardware
Flight controller, onboard companion computer and power board in a single stack: a triple-redundant, mission-critical design with standard interfaces for plug-and-play fit. In build today.
- Triple-redundant architecture
- Fabricated in India
- One stack across airframes and payloads
The battery: anodeless cells
Lithium plates directly onto the current collector, with no graphite anode, targeting a step-change in energy density for longer endurance and heavier payloads.
- Anodeless cell architecture
- Integrated BMS & thermal safety
- Longer endurance, heavier payloads
Five layers, one flight stack.
From the console that dispatches a fleet to the firmware that keeps a single aircraft stable — every layer is built to work as one system.
Mission & Fleet Operations
The operator layer: plan missions, task aircraft and follow every one of them in real time.
Autonomy & Perception
Live mapping, obstacle sensing, and path planning that let an aircraft understand the space around it.
Flight Control Firmware
The deterministic core that turns software decisions into stable, real-time flight.
Power & Propulsion
High-density energy storage and distribution, engineered for repeat, weight-critical flight cycles.
Airframe Integration
Sensors, actuators, and hardware interfaces that let the stack drop into new airframes fast.
From single drones to swarms.
Our flagship next step, in development alongside the core stack: every drone linked by swarm communications to a local ground control station, running on the same autonomy software.
In developmentOne operator, many drones
A single operator directs the whole swarm from a local ground control station.
Indoor swarm
Small drones working together inside buildings, tunnels and close quarters.
Outdoor swarm
Wide-area surveillance, plus delivery and logistics runs.
Perception unit
Onboard detection sends imagery to the GCS, where the operator confirms before any target is locked.
Fixed-wing UAVs
The same stack, with longer range and endurance for ISR and logistics.
The operator stays in command.
A local ground control station built alongside the swarm: one screen to plan, watch and decide, so autonomy does the flying while people make the calls.
In developmentLive swarm picture
Every aircraft’s position, status and health on one map, from a single drone to a full swarm.
Operator-confirmed decisions
Imagery from the onboard perception unit is shown for review; nothing is locked without the operator.
Mission tasking
Assign areas and routes to individual drones or the whole swarm, and re-task in flight.
Takeover at any moment
Step in on any aircraft instantly; pilot takeover and failsafes are always respected.
Swarm communications
Drone-to-drone and drone-to-GCS links keep the formation and the operator in sync.
Indigenous by design.
Every system SkaiAlly builds, from the autonomy stack to the flight controller and the battery, is designed in-house, with hardware fabricated in India through a trusted supply chain. No imported core behind an Indian label.
Owning the stack, start to finish
Many drones sold as Indian carry an imported flight controller, a licensed autopilot and foreign battery cells. We build all three in-house, on one team, because a self-flying machine can't afford a seam between the systems keeping it airborne.
Because the code is ours, it can be audited by the forces that depend on it. No black box, and no foreign supply line that can be cut when it's needed most.
- In-house PCB design
- Hardware fabricated in India
- Proprietary autonomy & flight software
- Auditable, indigenous IP